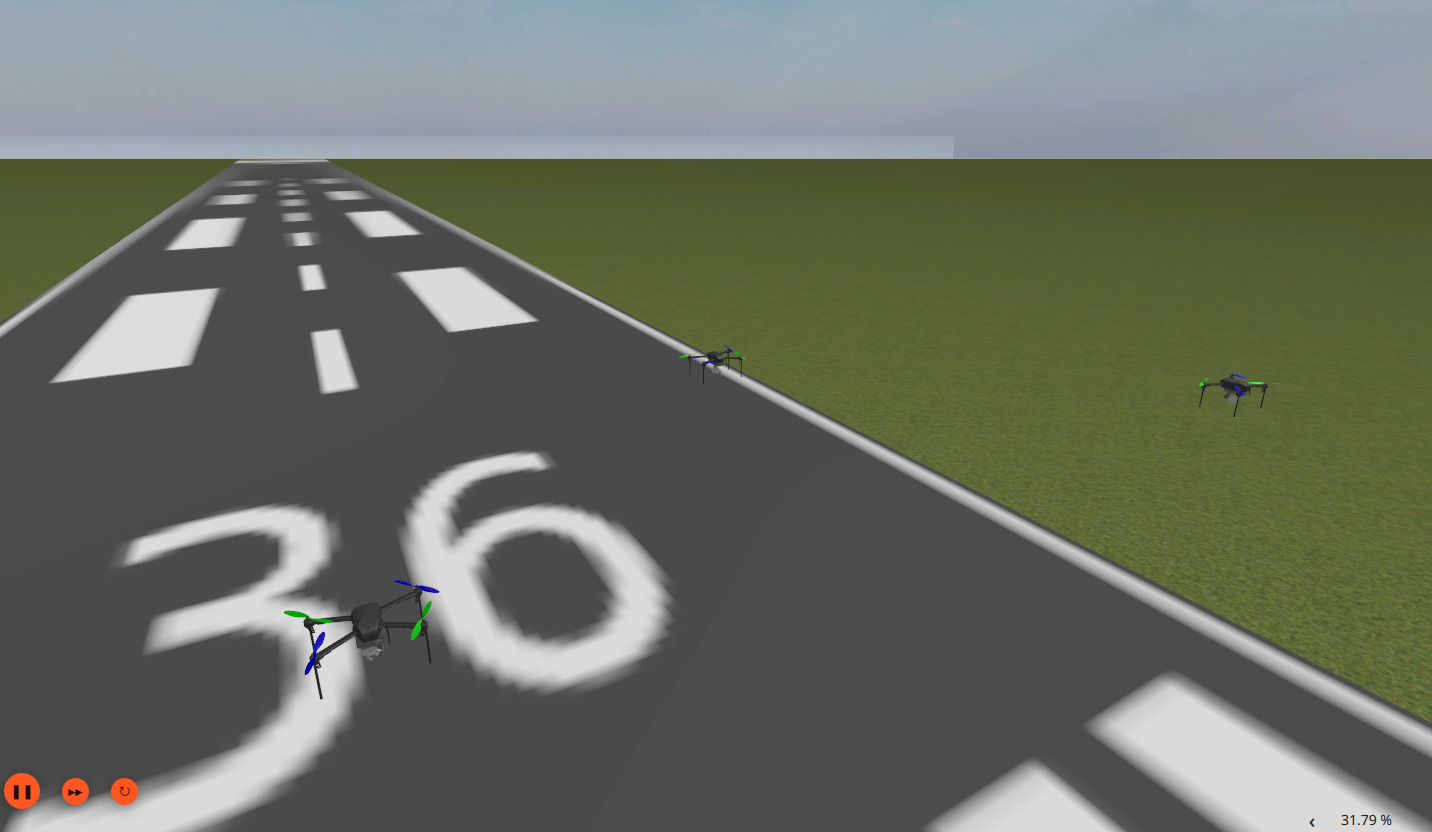
Contributed to a university team project simulating multi-drone formation control using ROS2, Gazebo, ArduPilot, and MAVROS. Our focus was on the control and communication layer: implementing the formation control algorithm that keeps multiple drones coordinated in flight, simulating ad-hoc communication between agents, and implementing event-based communication policies to govern how and when agents exchange information.
Beyond the control logic, I built a GUI-based remote control application in Tkinter for steering and monitoring the simulated drones in real time, including a target-input feature that lets a drone autonomously navigate to a specified coordinate. I also handled the complex system setup for the project, integrating ROS2, ArduPilot, and Gazebo into a working simulation environment, and presented the finished project with a live simulation demo to a university audience.